Payload profiles
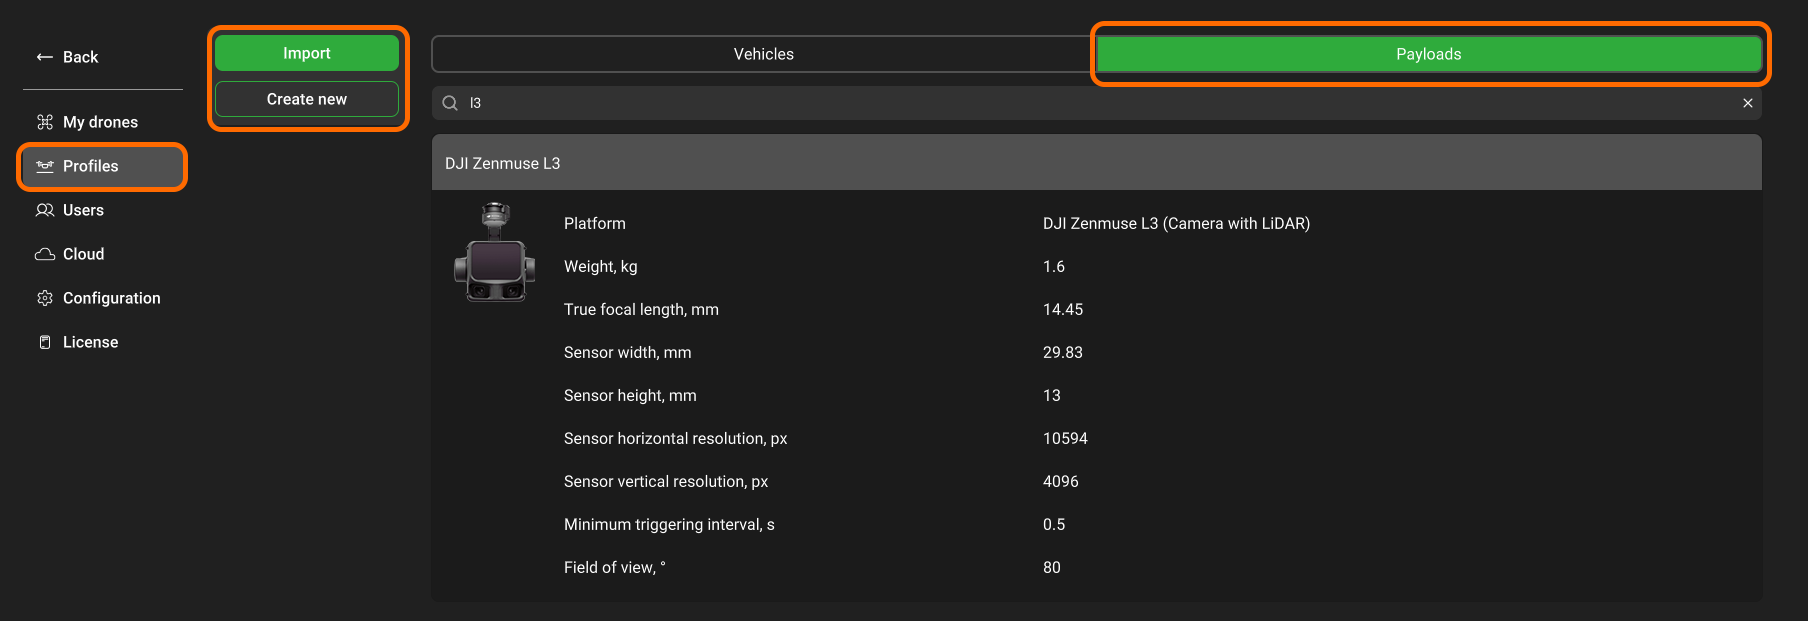
In the Main Menu's Profiles section, Payloads are listed as predefined payload cards. This section lets you create a new payload card defining the payload’s parameters.
To add a new payload, click the 'Create new' button, enter the required parameters and confirm with 'Save'.
To assign a payload to a certain vehicle profile, go to Main Menu -> Profiles -> Vehicles -> select the required vehicle -> click the 'Edit' button (pencil). In the vehicle card, click the 'Add' button and select the required payloads from the list. You can add several payload profiles to a single vehicle profile. After the payload is added, click 'Save'.
Payload parameter description
| Parameter | Description | Mandatory |
|---|---|---|
| Payload name | User-defined payload name | Yes |
| Weight | Camera weight, kg | Yes |
| True focal length, mm | True focal length | Yes |
| Sensor width, mm | Physical sensor width in metric units | Yes |
| Sensor height, mm | Physical sensor height in metric units | Yes |
| Sensor horizontal resolution, px | Sensor horizontal resolution in pixels | Yes |
| Sensor vertical resolution, px | Sensor vertical resolution in pixels | Yes |
| Minimum triggering interval | Minimum time interval between two neighbouring shots | Yes |
| Field of view, ° (is only available for LiDARs) | A visible extent of the scene captured by the image sensor, stated as an angle | Yes |
Payload importing/exporting
The payload profile import/export feature allows easy adding of profiles for cameras that are not in UgCS by default. This can be used by both payload manufacturers as well as customers using custom payloads with UgCS.
The camera parameters in UgCS include sensor size, focal distance, and minimum triggering interval. Correct payload parameters are necessary to ensure proper overlap between images, accurate flight altitude for the set GSD, and less frequent triggering of the camera than it physically allows.
Updated 12 days ago